Doppler velocity log
A DVL estimates velocity relative to the seabed or water mass. POSIM uses Gazebo's DVL system and a ROS bridge that converts observations to posim_interfaces/msg/DVL.
Run the sensor
ros2 launch posim_demos posim_sensor.launch.py \
  namespace:=nortek_dvl500_300 world_name:=dvl_world z:=-30 \
  paused:=false gui:=false headless:=true
In a second sourced terminal, inspect Gazebo and then ROS data:
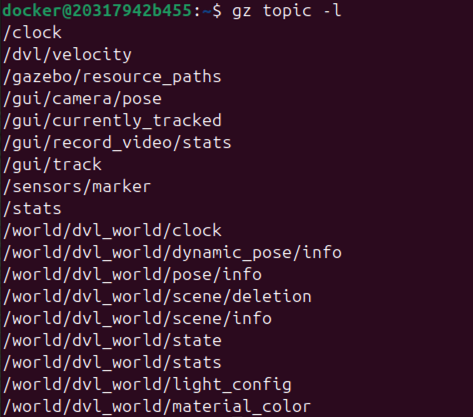
gz topic -e -t /dvl/velocity
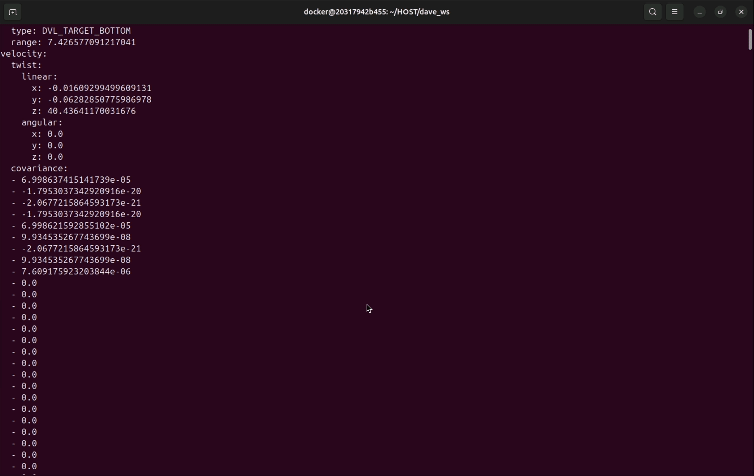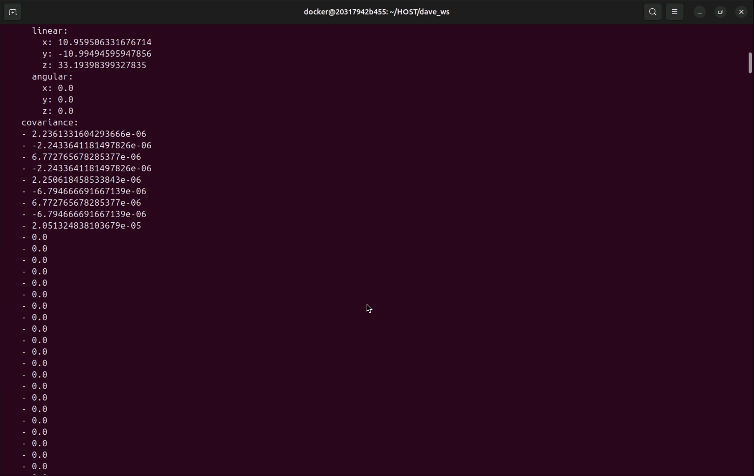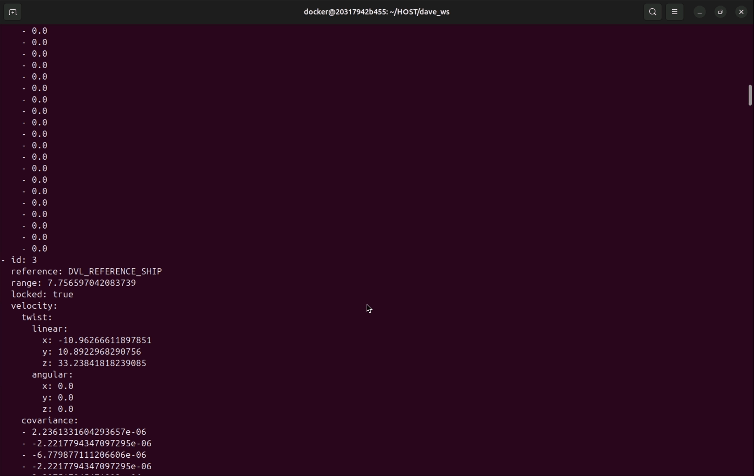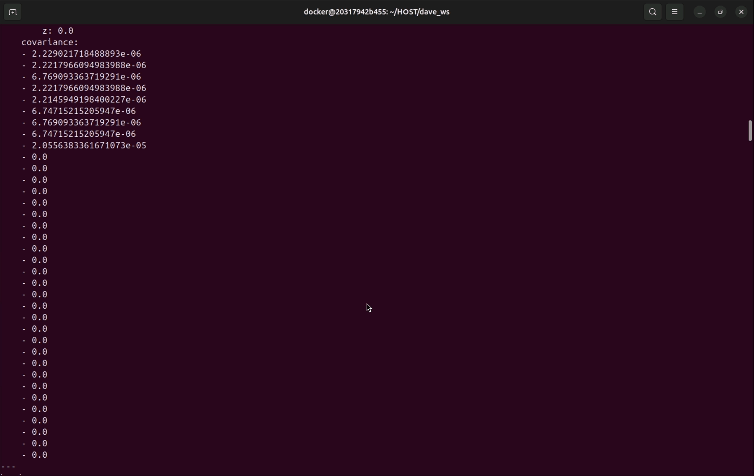
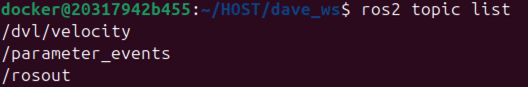
ros2 topic echo /dvl/velocity posim_interfaces/msg/DVL --once
Stop the Gazebo viewer before the ROS command. Match the topic to your descriptor if you create a new sensor.
Available descriptions
| Description | Configuration family |
|---|---|
nortek_dvl500_300 |
Nortek DVL500 |
nortek_dvl500_6000 |
Nortek DVL500 |
nortek_dvl1000_300 |
Nortek DVL1000 |
nortek_dvl1000_4000 |
Nortek DVL1000 |
sonardyne_syrinx600 |
Sonardyne |
teledyne_explorer1000 |
Teledyne Explorer |
teledyne_explorer4000 |
Teledyne Explorer |
teledyne_whn |
Teledyne WHN |
nortek_dvl500_300_with_multibeam_sonar |
DVL plus CUDA sonar |
Check each sensor model's sampling and geometry in SDF.
Configure a DVL
Configure gz:type="dvl" with beam angles/tilt, bottom/water tracking, velocity noise and reference frame.
- DVL500-300 requested rate: 8 Hz
- Range: 0.3–200 m
The example converts ENU to its configured forward/starboard/down reference using <reference_frame>. The ROS bridge preserves the Gazebo frame ID. Check that your estimator uses the same frame and distinguishes bottom tracking from water-mass tracking.
Inspect observations
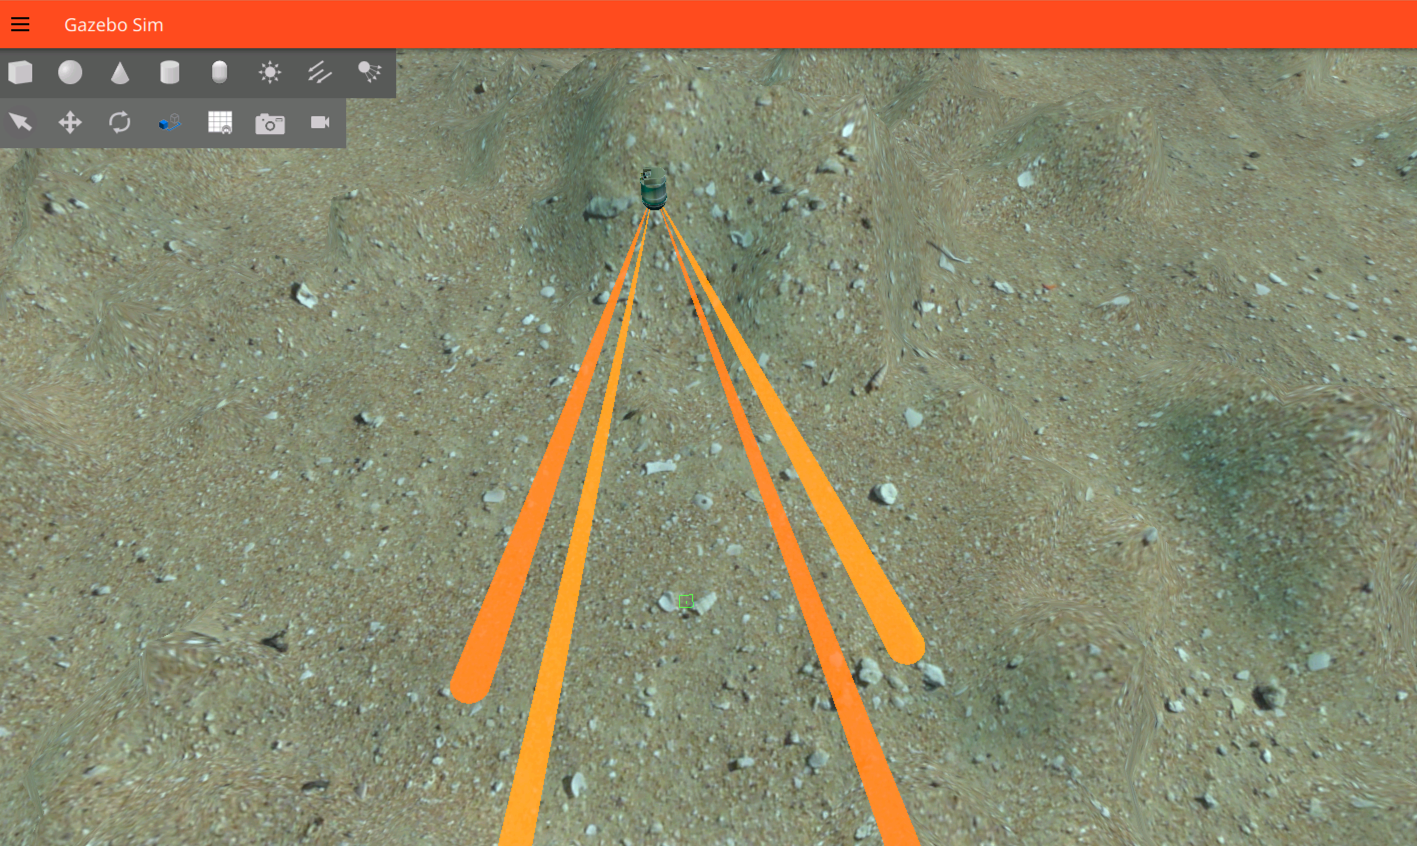
Use ros2 interface show posim_interfaces/msg/DVL for the payload definition. Confirm received velocity, frame and status with a known stationary case, then a controlled translation. Bottom geometry, range and beam intersections affect the observations. Enable the descriptor's visualization settings when inspecting beams on a configured desktop.
DVL beams and output
Figures and videos: POSIM Notion Wiki. See Citation and licenses for DAVE documentation attribution. Use this page's code blocks for execution commands and topic names.