Platform for Ocean Simulation
POSIM is a ROS 2 and Gazebo library for maritime robotics, derived from Project DAVE. DAVE builds on UUV Simulator. Combine ocean environments, robots, simulated sensors and control interfaces for repeatable experiments.
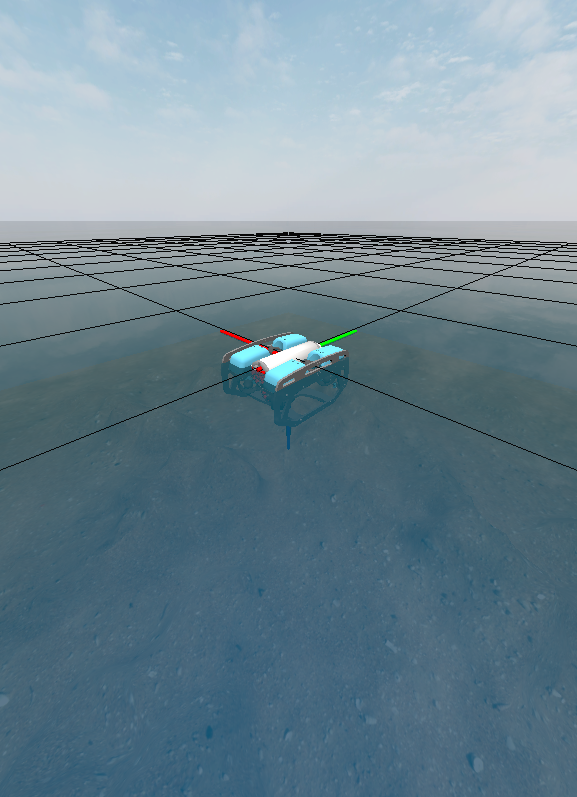 ROV · BlueROV2
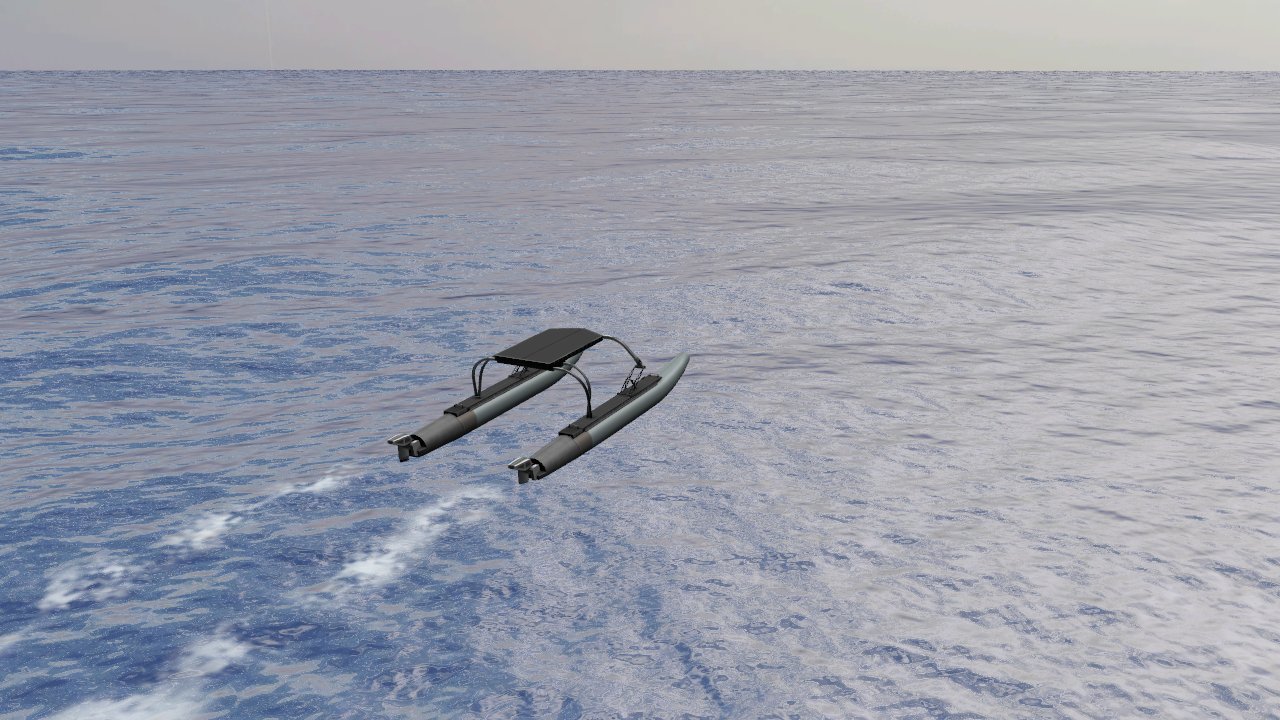 Surface robot · WAM-V
 Seabed · Task scenes
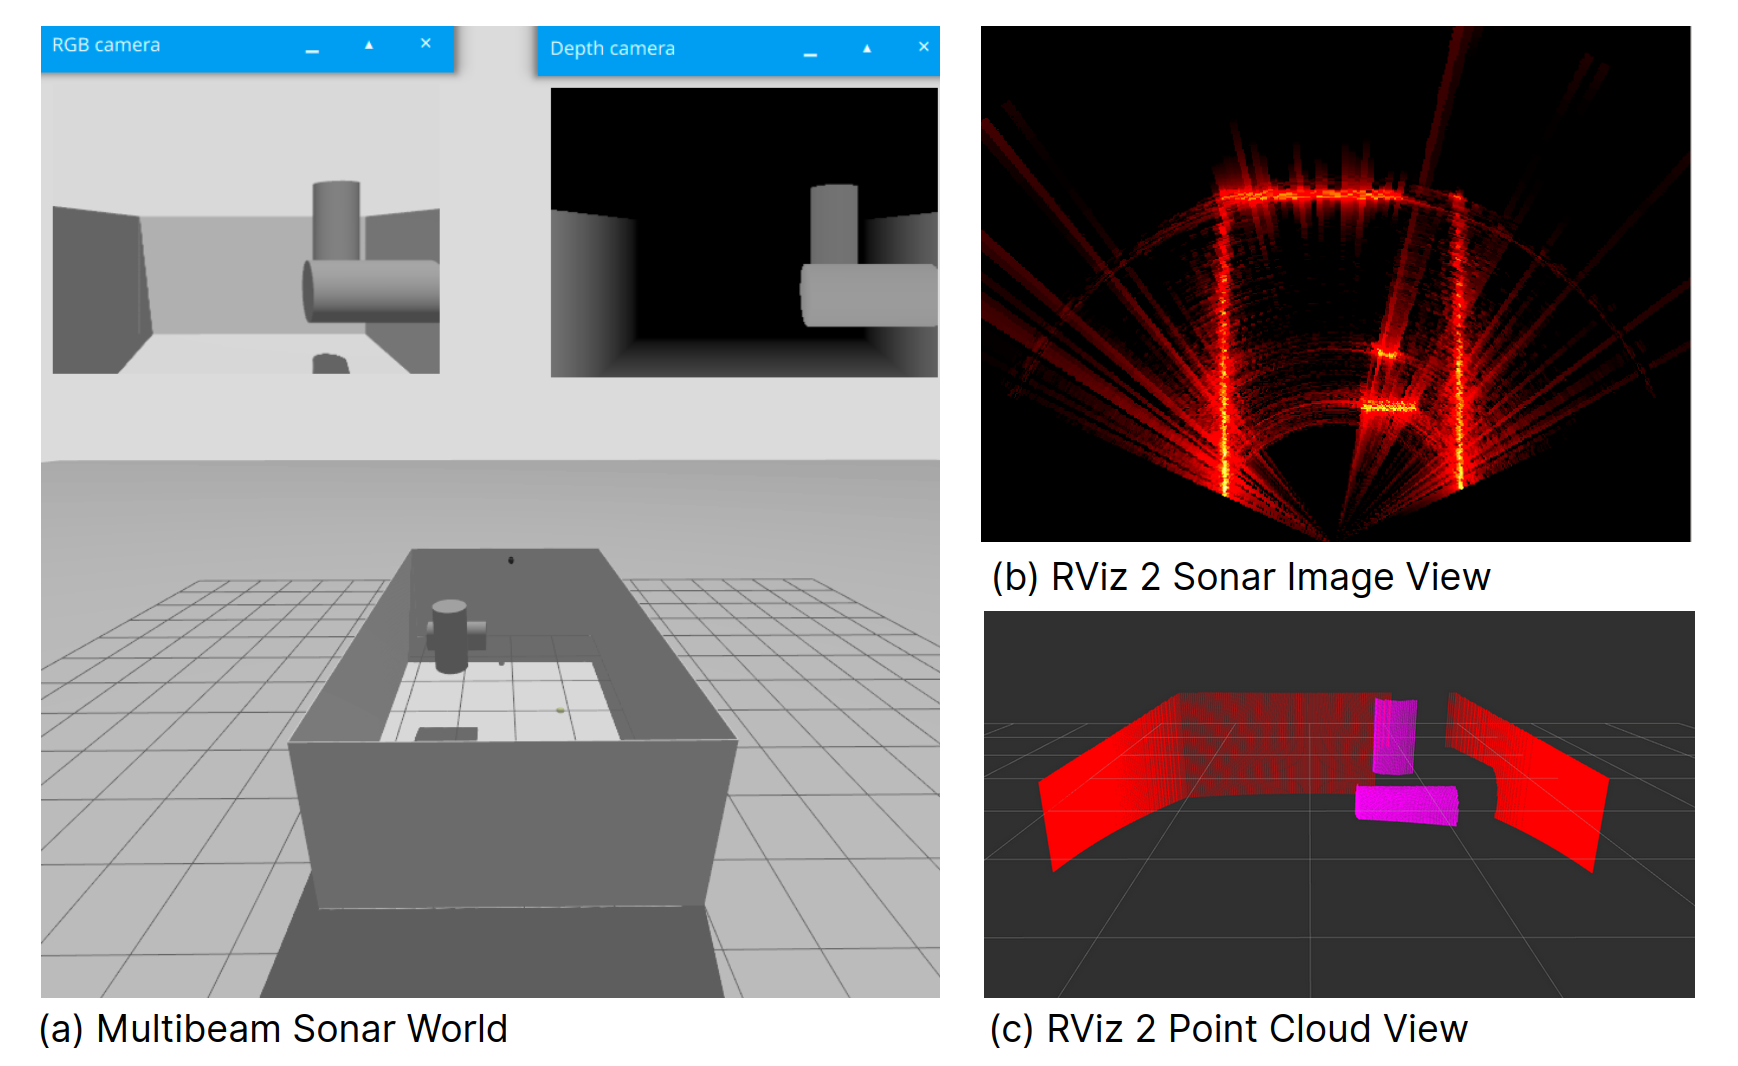 Sonar · Imagery and point clouds
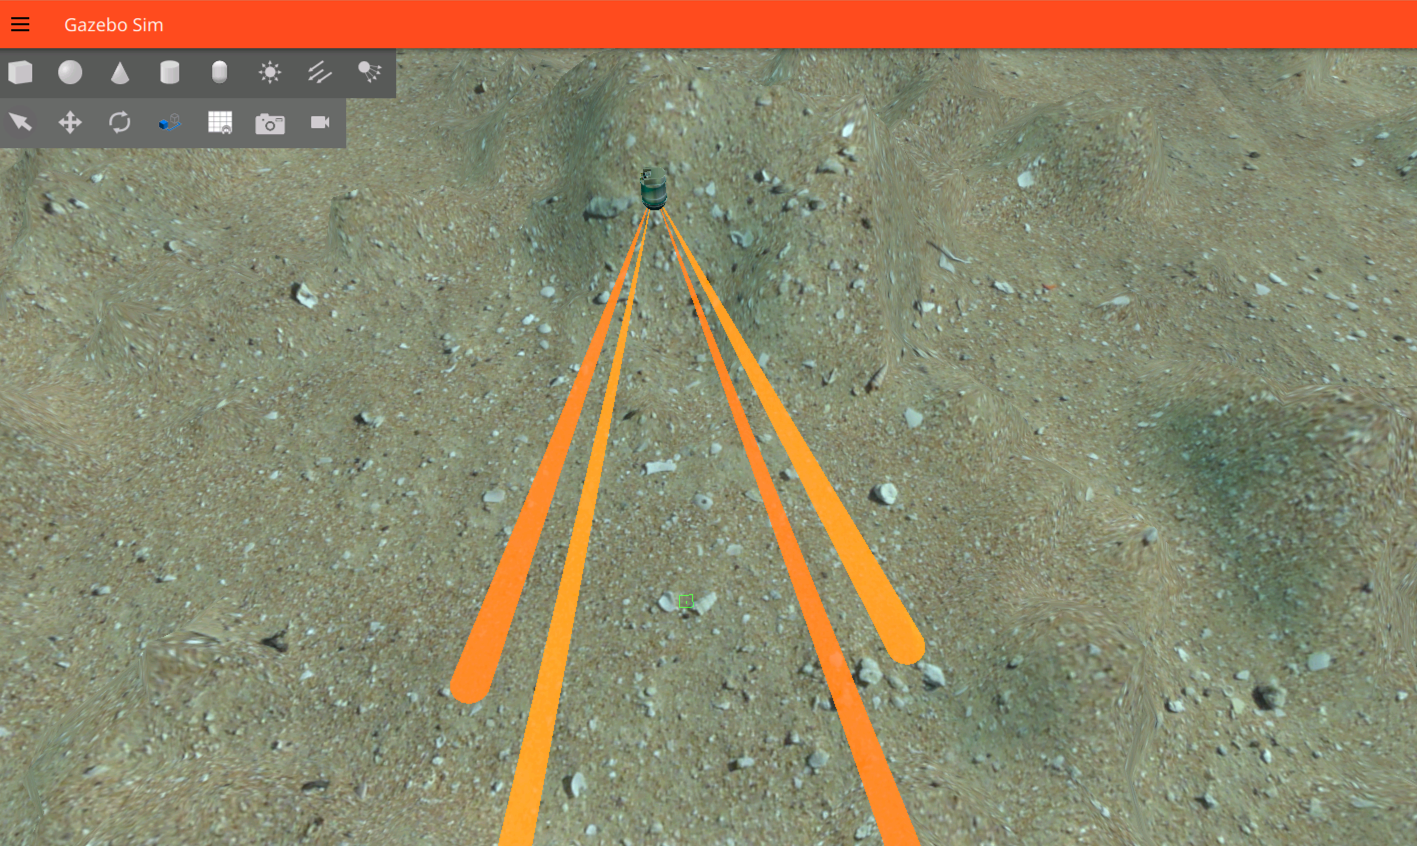 DVL · Velocity sensing
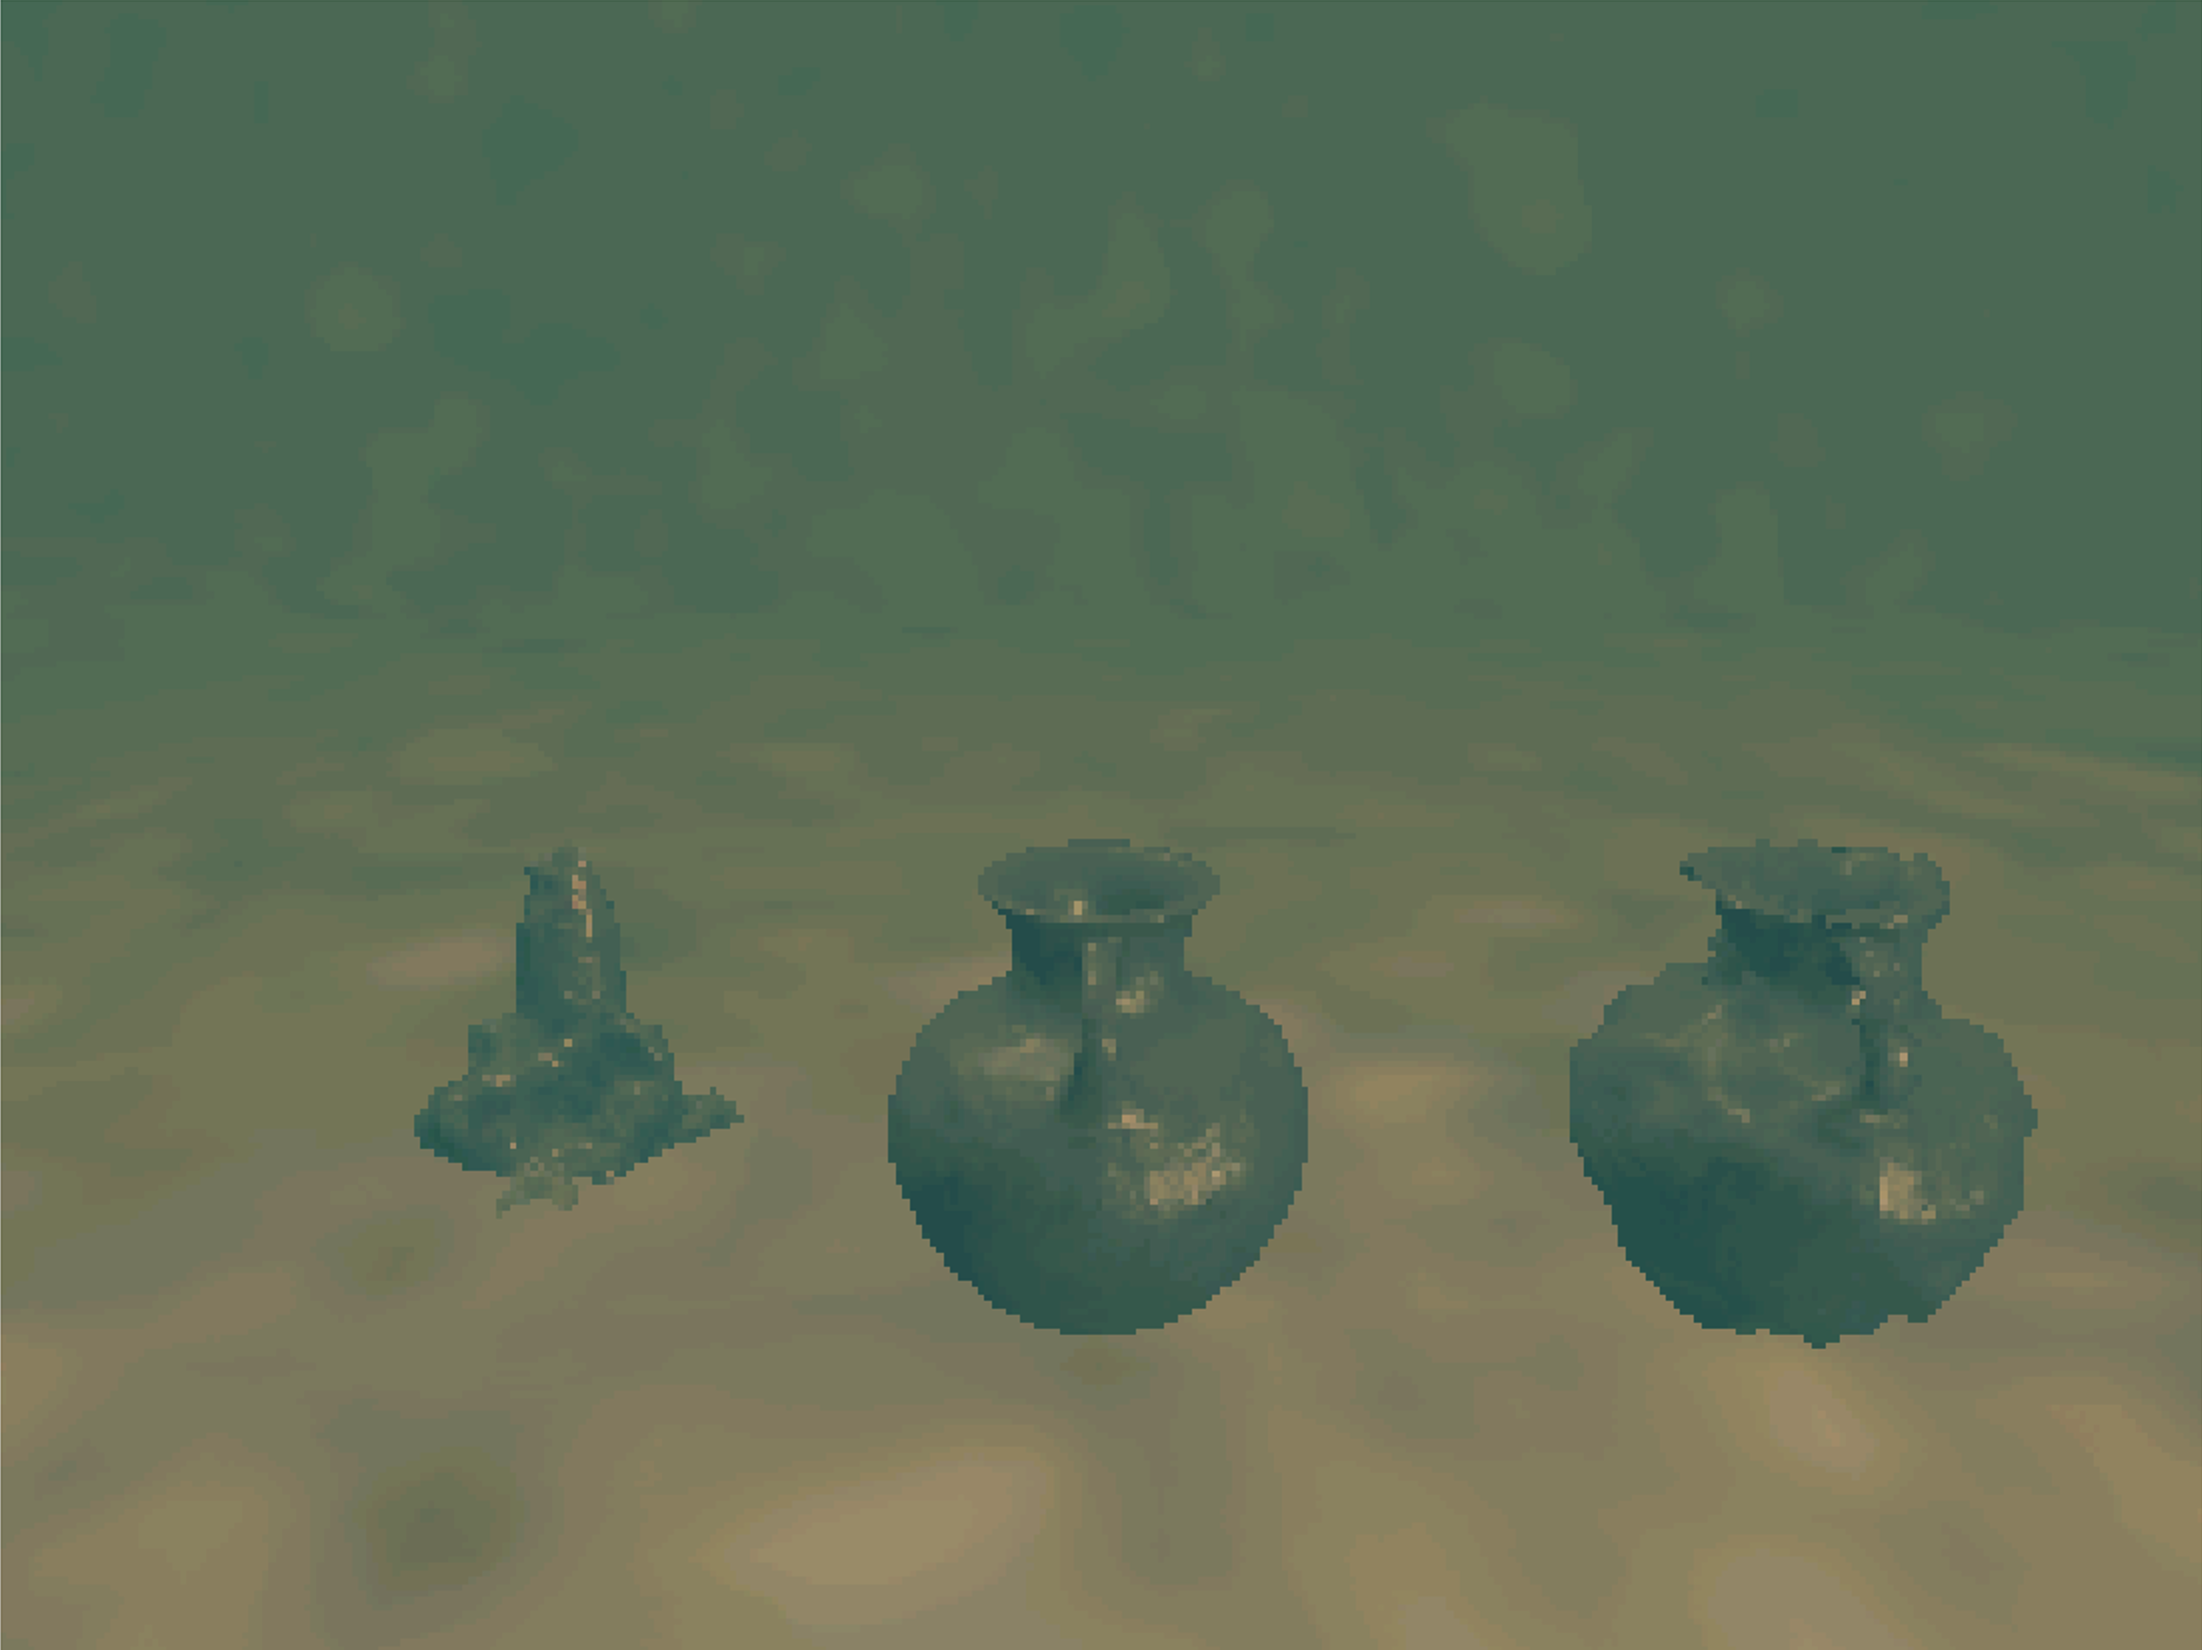 Camera · Underwater vision
Try WWW-POSIM
WWW-POSIM is an ocean robot simulator powered by POSIM. Use a web workspace or desktop app.
- Generate seabed and coast from latitude/longitude
- Operate surface/underwater robots and inspect sensors
- Test ArduPilot waypoint missions or ROS 2 code
- Watch the public LIVE world voyage
Start here
Prepare an Ubuntu installation or Docker environment, then run the first simulation.
- Operating system: Ubuntu 26.04
- ROS: ROS 2 Lyrical
- Simulator: Gazebo Jetty
Library components
| Component | Purpose | Guide |
|---|---|---|
| Ocean worlds | Surface, seabed and task scenes | World library |
| Robots | REXROV, BlueROV2, Slocum and surface vehicles | ROVs, Gliders, Surface robots |
| Sensors | Camera, DVL, pressure, USBL and CUDA sonar | Camera, DVL, Sonar |
| Environment plugins | Currents and geographic coordinates | Currents, Coordinates |
| ROS interfaces | Sensor subscriptions, commands and recording | ROS 2 and control |
Simulation structure
- Define the environment and world systems in world SDF.
- Define links, collision, inertia and sensors in model SDF.
- Launch Gazebo, the model and ROS bridges.
- Subscribe to sensors and send commands from ROS nodes.
Use POSIM directly in a ROS workspace. WWW-POSIM provides geographic world generation, a workbench and online sessions.
WWW-POSIM uses POSIM-Terrain, POSIM-Routing and POSIM-Control for terrain generation, route planning and vehicle control. Each is a public library with its own usage guide.
Find a guide
- Examples: commands and data checks
- Advanced guides: models, terrain and build settings
- Plugin reference: values, units and topics
- Contributing: source/documentation updates and checks
Each page links related source and reference material in its footer.